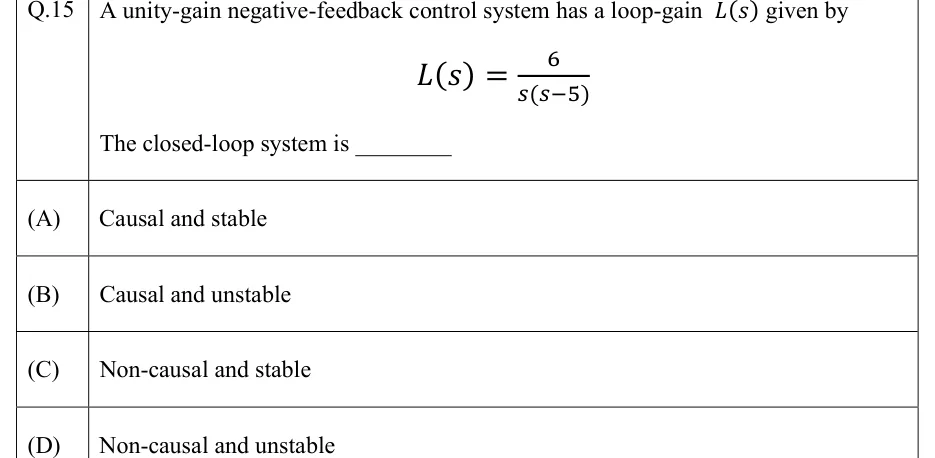
A unity-gain negative-feedback control system has a loop-gain given by
The closed-loop system is ________
- (A)
Causal and stable
- (B)
Causal and unstable
- (C)
Non-causal and stable
- (D)
Non-causal and unstable

A unity-gain negative-feedback control system has a loop-gain given by
The closed-loop system is ________
Causal and stable
Causal and unstable
Non-causal and stable
Non-causal and unstable
ANSWER
The closed-loop characteristic equation is . Both poles are in the right half-plane and the system is physically realised, so it is causal and unstable. The answer is (B).
Official answer: BSource: Official answer key, GATE 2022 IN (IIT Kharagpur)
Closed-loop transfer function (unity negative feedback):
Characteristic equation: .
Routh array: row : ; row : ; row : . The first column is . It changes sign twice ( and ), so there are two right-half-plane poles.
Check by factoring: , so the closed-loop poles are and . Both lie in the right half-plane, so the closed loop is unstable.
(Quick check without Routh: a second-order polynomial is Hurwitz only when all its coefficients have the same sign. Here they are , so instability is clear straight away.)
Causality: is a strictly proper rational function (numerator degree < denominator degree ). It comes from a physical feedback loop built around a causal plant, so its region of convergence is the right-sided one, , and its impulse response is zero for . The system is therefore causal. Instability does not make it non-causal. The growing modes and exist only for . It is unstable because the ROC does not contain the axis.
So the closed-loop system is causal and unstable, which is option (B).
KEY IDEA
Stability depends on the closed-loop poles, which are the roots of , not the open-loop poles. Here they are and , so the system is unstable. Causality is a separate property. A feedback system built from causal physical parts is always causal, and its right-sided ROC () leaves out the axis, which is why it is unstable.
WATCH OUT FOR
Treating instability as if it meant non-causality and choosing (D). Another mistake is judging stability from the open-loop pole at alone, or thinking that feedback with positive gain must stabilise it. The closed-loop polynomial has mixed-sign coefficients, so the closed loop is still unstable.
From the GATE 2022 IN paper. Every question of this paper · Download the full paper · All 15 Routh–Hurwitz questions, with notes